Frame-to-Event Conversion Framework
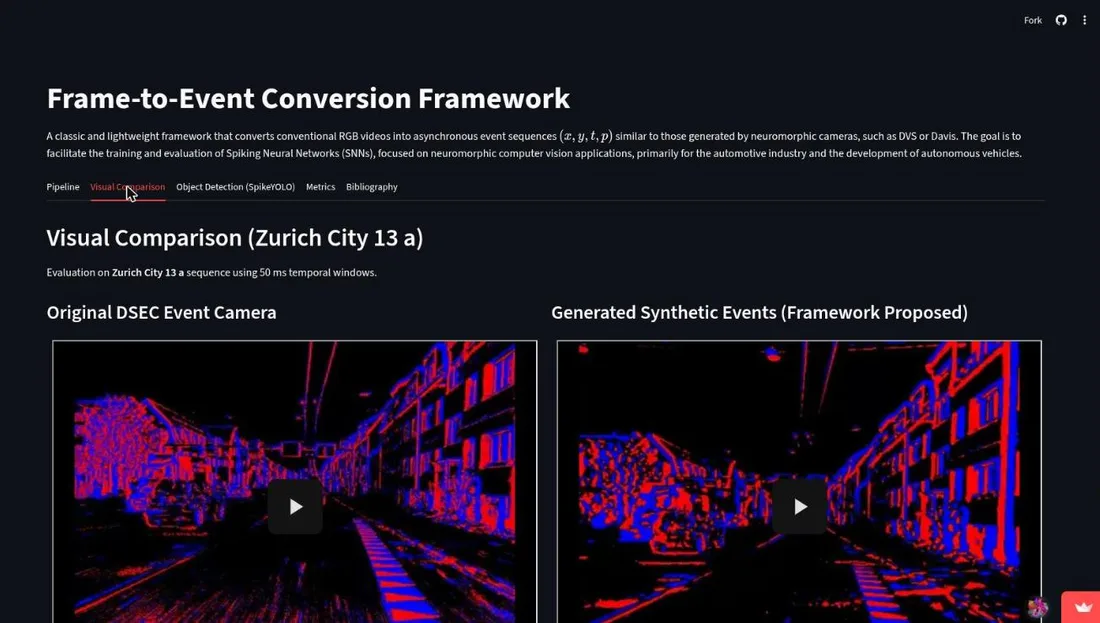
Converts conventional RGB video into asynchronous event streams (x, y, t, p) like those from neuromorphic cameras such as DVS and DAVIS, using a classical computer-vision pipeline rather than deep learning. Built to generate synthetic training data for spiking neural networks in automotive vision, and benchmarked against real DSEC event-camera recordings.
Technologies
- Python
- Streamlit
- OpenCV
- NumPy
- PyTorch
Main features
- Classical pipeline: grayscale, log intensity, Gaussian blur, frame differencing, and thresholding
- Per-pixel polarity events (+1 / -1) with microsecond-precision timestamps
- HDF5 event-stream output plus rendered MP4 visualizations
- Configurable contrast threshold, minimum pixel count, and frame resizing
- Side-by-side benchmarking against real DSEC event-camera ground truth
- SpikeYOLO object-detection evaluation on the generated event data